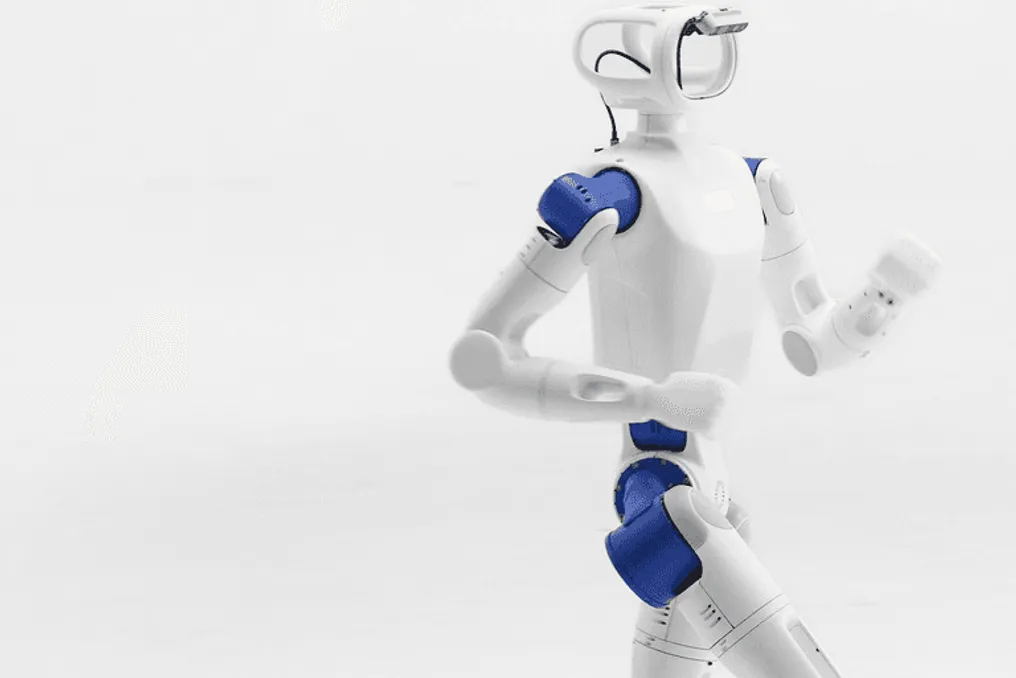
Noetix Robotics has introduced a humanoid robot priced at RMB9,998 to buyers, offering a product previously available only in research laboratories, corporate demonstrations, or expensive technology exhibitions.
The small robot named Bumi, presented by the Chinese company in October 2025, was aimed at educational programming and companionship sectors. Its appeal lay in a simple proposition: children could program the robot's movements, watch it dance, and interact with the machine, which resembled a small human both externally and functionally.
This approach also reflected a broader vision for building a robotics company: first making the chassis affordable and sufficiently functional for sale, while more complex intelligence would be developed later. Over three years since its founding, the company has strived to turn this sequence into a large business by increasing supply volumes, investing in its own embodied intelligence models, and seeking international clients.
In October, media reports surfaced that Noetix had confidentially filed an application for listing in Hong Kong, potentially targeting an IPO in 2027. The central question linking these ambitions is whether the initially established hardware business can secure enough customers, experience, and capital to support further development.
Founder Jian Zheyuan completed his doctoral studies at Tsinghua University in 2023 and founded Noetix in September of the same year. His initial technical priority was focused on the robot's chassis and motion control—the mechanics and software allowing the robot to balance, move, and react stably.
It is important to distinguish these tasks: a robot can perform complex movements relying on external models for communication or high-level instructions, but creating an athletic machine differs from creating one capable of making autonomous decisions in an unfamiliar room. Jian's decision was to first solve the physical machine problem. He explained that in the early stages, the main bottlenecks for the company were unreliable chassis and limited production readiness. Furthermore, AI approaches were rapidly evolving, so Noetix concentrated resources on hardware, awaiting clearer direction in the intelligence stack.
Low cost was part of this engineering task. In a March interview, Jian discussed using composite materials in Bumi's chassis to reduce reliance on metal structures. The price was built into the design, not left for sales department negotiations after production. This approach allowed the company to have a product with a clear purpose: parents and schools could purchase a programmable humanoid robot for learning and interaction without waiting for general-purpose domestic robots to become commercially viable.
A narrower use case helped Noetix reach buyers faster. This also defined the next commercial objective: providing these buyers with sufficient ongoing value so that the robot became more than just an exciting first purchase.
Noetix's machines attracted widespread attention due to their performance. The N2 robot finished second in the Beijing Humanoid Robot Half Marathon in 2025. In 2026, the company's robots appeared in a sketch at the Chinese New Year Gala alongside comedian Cai Ming. This exposure linked technical demonstrations with a mass audience: the robot seen by families on television was also available through retail channels.
At the AWE exhibition in March, Jian stated that orders surged after the gala, and the company set a goal to sell over 10,000 units of Bumi during 2026. The company was transitioning from proving that people would pay attention to its robots to demonstrating the ability to supply them consistently.
Jian's description of obstacles was surprisingly practical. He cited component availability and production line management as central issues. A missing part can halt the assembly of an entire machine. As monthly production volume grows, the company must train and manage a larger staff while maintaining build quality. These issues have serious implications for a company whose market entry depends on accessibility. Every reworked unit, delivery delay, or service visit consumes some of the margin left at the low selling price.
Thus, the production goal is more significant than merely reaching a shipment milestone. It tests Noetix's ability to maintain the economy embedded in Bumi while manufacturing and supporting it in much larger quantities.
By September, Noetix made a clear next technical commitment: it launched the embodied intelligence sub-brand Scalabot and the HERON world modeling architecture, expanding its ambitions regarding how robots perceive their environment and learn to act within it. According to Jian's interview with Caijing in September, the company began assembling a specialized intelligence team back in July 2025. This work added a substantial research program to an organization already scaling physical production.
His logic connects these two activities. Cheaper and more reliable machines can be deployed more widely; these deployments can create opportunities for gathering experience to train better models. Turning this link into productive activity requires another layer of engineering. The robot in the class generates experience, but the useful training data still needs to be selected, recorded, organized, and mapped to the tasks the company wants its models to master. A large installed base provides access to potential data, and the collection and training system determines its value.
Jian told the 21st Century Business Herald that intelligence research has become a major expense item. He also noted that the hardware can serve as a source of funding for this work. This is a financial lever of Noetix's strategy. The chassis-oriented approach opened an earlier path to revenue. Now, the company wants this operational business to help sustain the more costly efforts whose commercial returns will take longer.
External capital helps bridge the time lag. Among its sponsors are Chendao Capital, an investment platform associated with CATL. A potential listing in Hong Kong will shift this financing process to public markets, where investors can examine in greater detail the relationship between hardware sales and research expenditures.
Noetix's internal path combined educational demand, accessible hardware, and unusually broad public resonance. Its overseas expansion will test how well this combination translates abroad. At the CES exhibition in January, co-founder Zhang Shipu identified five target regions: North America, Europe, the Middle East, Southeast Asia, Japan, and South Korea. He stated the aim to achieve thousands of units in overseas expansion by the second quarter, supported by local implementations, customer service, and repeatable reference projects.
This program involves more than just exporting robots. Schools require teaching materials and support. Distributors need spare parts and repair agreements. Families need an incentive to continue using the product after the novelty wears off. Noetix already has some of these connections that can be developed in China. Investor Beijing Industrial Development Investment Management reported partnerships with the coding education provider Codemao and retailer Kidswant, as well as implementations and donations in schools. These connections demonstrate how the robot can become part of an existing educational or retail system.
Overseas growth will require similar connections in markets with different curricula, languages, and purchasing habits. Product price might attract attention, but local utility and support will determine if that attention becomes a sustainable business. Noetix's first step was to make the humanoid robot accessible enough to penetrate more classrooms and homes. This choice gave it a product to sell while the broader intelligence problem was under development. Now, the company is trying to make this early foothold accomplish three tasks simultaneously: increasing production volume, enhancing intelligence capabilities, and achieving international growth. Establishing the chassis first secured Noetix's place in the market. The next stage is to make that position valuable enough to fund everything else it wants from the robot.