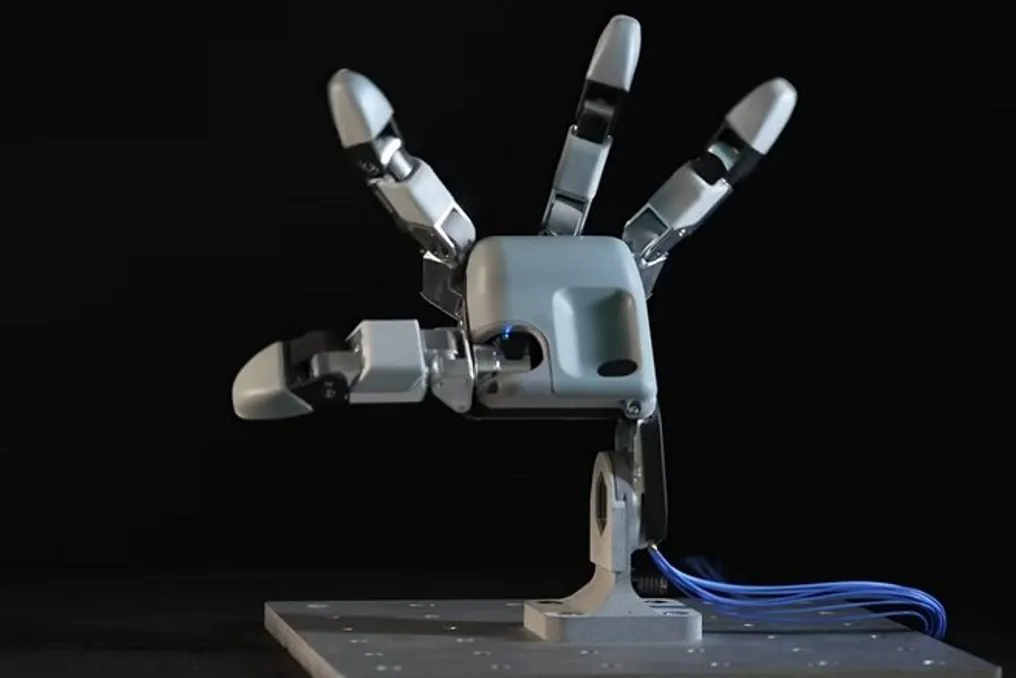
Boston Dynamics has demonstrated an updated gripper for its humanoid robot Atlas. The new design features four fingers (compared to three in the previous model) and has 13 degrees of freedom instead of the former seven.
According to information published on the company's blog, this improvement allows the robot to perform a number of complex manipulations: rotating objects in its hand, catching them if they start to slip, holding tools such as a drill or welding torch, and simultaneously pressing buttons located on these tools.
The decision to exclude the pinky finger was made by engineers after conducting a special experiment. Company employees monitored the connection of the pinky fingers to the ring fingers for one day to assess what functions become unavailable in that state.
As a result of this testing, the team concluded that the potential benefit of adding another finger does not compensate for the need to install three additional actuators.